
Overview
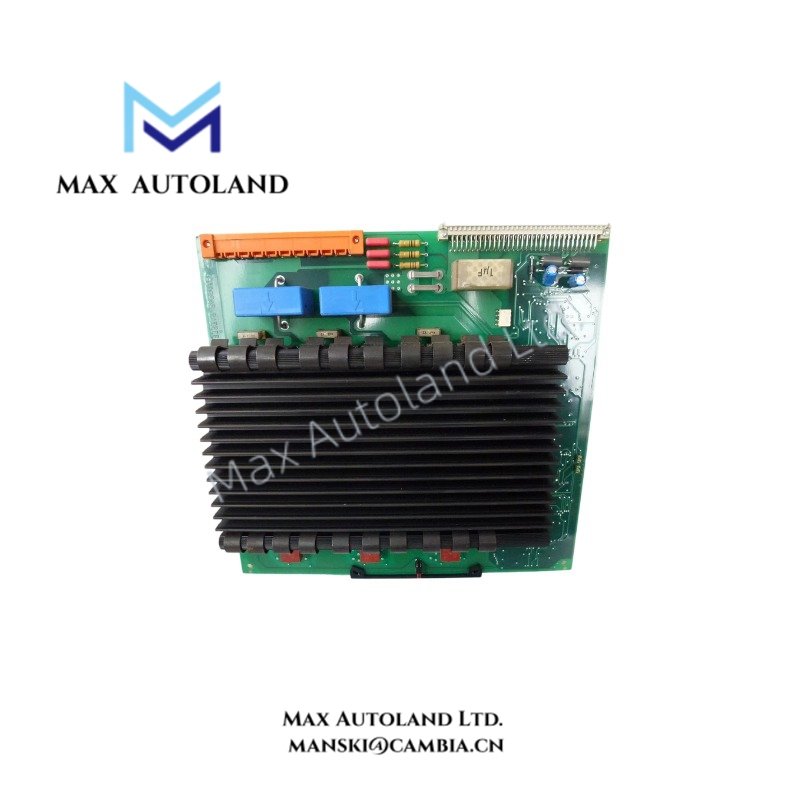
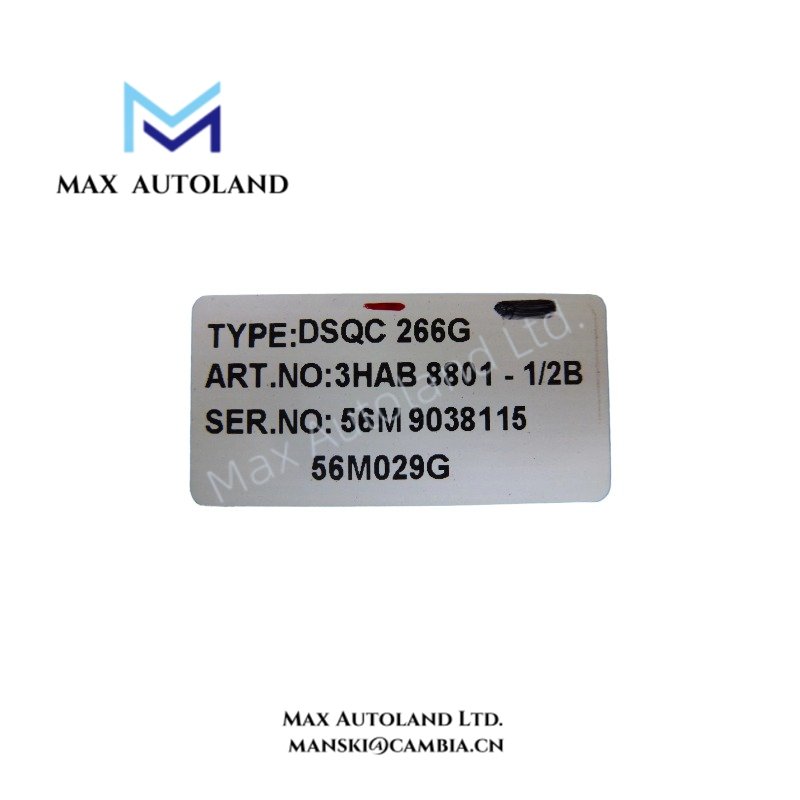
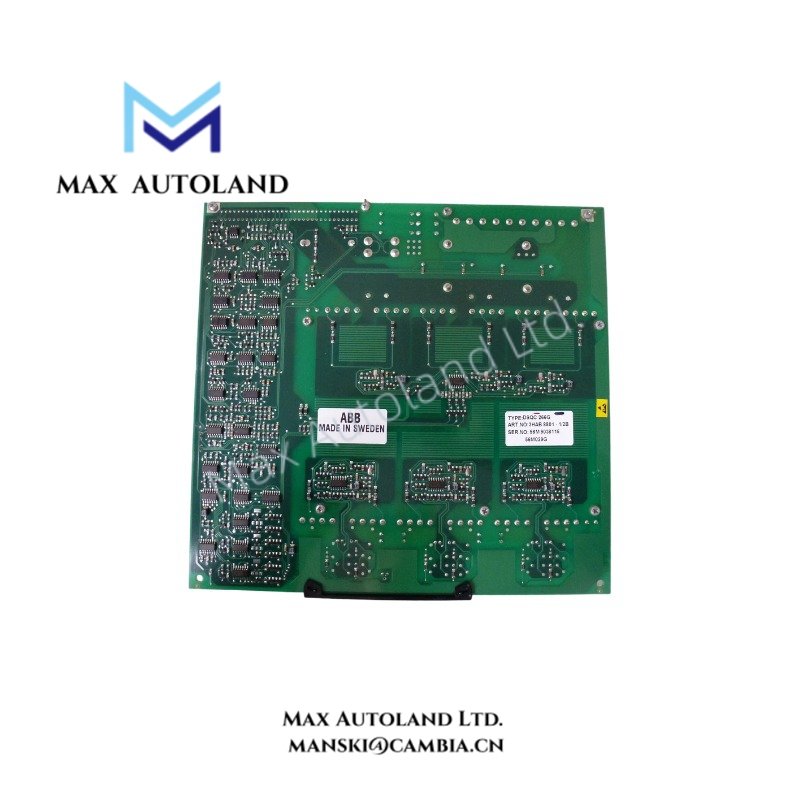
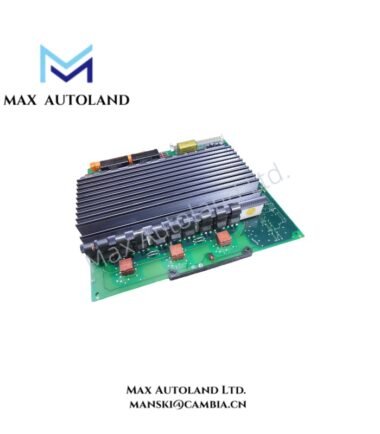
The ABB DSQC266G 3HAB8801-1, also identified by the base model DSQC266G, is a servo control board for robotic motion control within ABB robot control systems. It processes encoder feedback and motion commands to regulate position, velocity, and torque. The supplied specifications list a 62.5 us control-loop update rate, 24-bit position resolution, and a robot system bus operating at 12 Mbps.
Hardware Specifications
| Parameter | Specification |
|---|---|
| Model | DSQC266G |
| Part Number | 3HAB8801-1 |
| Brand | ABB |
| Product Type | Servo Control Board |
| Origin | Sweden |
| Weight | 0.4 kg |
| Dimensions | 28 x 20.3 x 2.7 cm (estimated shipping size) |
| Operating Temp | 0 to +55 deg C |
| Operating Voltage | 24 VDC +/- 10% (provided data) |
| Power Consumption | 15 W typical (provided data) |
| Memory | 64 MB DDR3 RAM, 16 MB Flash (provided data) |
| Control Loop Update Rate | 62.5 us (provided data) |
| Position Resolution | 24-bit, 0.0001 deg (provided data) |
| Velocity Ripple | Less than 0.02% of rated speed (provided data) |
| Torque Control Accuracy | +/- 0.5% of rated torque (provided data) |
| Motor Outputs | 3-phase PWM, up to 20 kHz (provided data) |
| Encoder Inputs | 2 x EnDat 2.2 / SSI, 26-bit (provided data) |
| Digital Inputs | 8 x 24 VDC (provided data) |
| Digital Outputs | 4 x 0.5 A (provided data) |
| Robot System Bus | 12 Mbps |
| Vibration | 5 g at 5-200 Hz (provided data) |
| HS Code | 8537101190 |
| Place of Shipment | Xiamen, China |
Robot Motion Control and Bus Communication
The servo control function uses position feedback and motion commands to regulate motor movement. Encoder feedback supports position and velocity monitoring, while the control loop processes motion-control updates at the specified interval.
The supplied data identifies EnDat 2.2 and SSI encoder interfaces, along with a 12 Mbps robot system bus. These interfaces must match the connected encoder hardware and the controller’s communication architecture.
The listed 3-phase PWM output frequency of up to 20 kHz describes the stated motor-control output capability. The actual motor interface, supported drive configuration, and electrical connections must be verified against the applicable ABB hardware documentation.
Frequently Asked Questions (FAQ)
Q: What encoder interfaces are listed for the DSQC266G?
A: The supplied specifications list two encoder inputs supporting EnDat 2.2 or SSI, with a stated 26-bit resolution. Confirm the supported interface configuration and encoder compatibility before installation.
Q: What is the specified robot system bus speed?
A: The supplied data specifies a robot system bus speed of 12 Mbps. Confirm controller compatibility and the applicable bus configuration using the system documentation.
Q: Can the board be replaced while the robot controller is energized?
A: Hot-swap capability is not established by the supplied specifications. Isolate power and follow the ABB service procedure unless the applicable controller documentation explicitly permits energized replacement.
Field Installation Guidelines
- Verify hardware identity: Confirm the DSQC266G model and 3HAB8801-1 part number against the existing board and controller documentation.
- Isolate electrical power: Follow the robot controller’s shutdown and lockout procedures before removing or installing the board.
- Inspect connections: Check connectors, contacts, and the board surface for contamination, damage, or loose components.
- Verify encoder compatibility: Match the connected encoder type and interface configuration to the controller documentation.
- Check signal wiring: Route encoder feedback and digital I/O wiring according to the specified electrical interface. Separate sensitive signal wiring from motor power conductors where practical.
- Check grounding and shielding: Follow ABB’s grounding and cable-shield termination requirements for the specific controller and encoder installation.
- Validate operation: After installation, inspect controller diagnostics and verify encoder feedback, motor-control response, and digital I/O operation before returning the robot to service.
Documentation note: The detailed memory, PWM, encoder-resolution, and torque-control figures above are reproduced from the supplied data and have not been independently verified against an ABB datasheet for 3HAB8801-1. Confirm these values before using them for engineering design or board interchangeability decisions.
ABB Top Products
Customers Also Viewed
Contact: Manski Wong +86 18030205725 manski@cambia.cn


Reviews
There are no reviews yet.